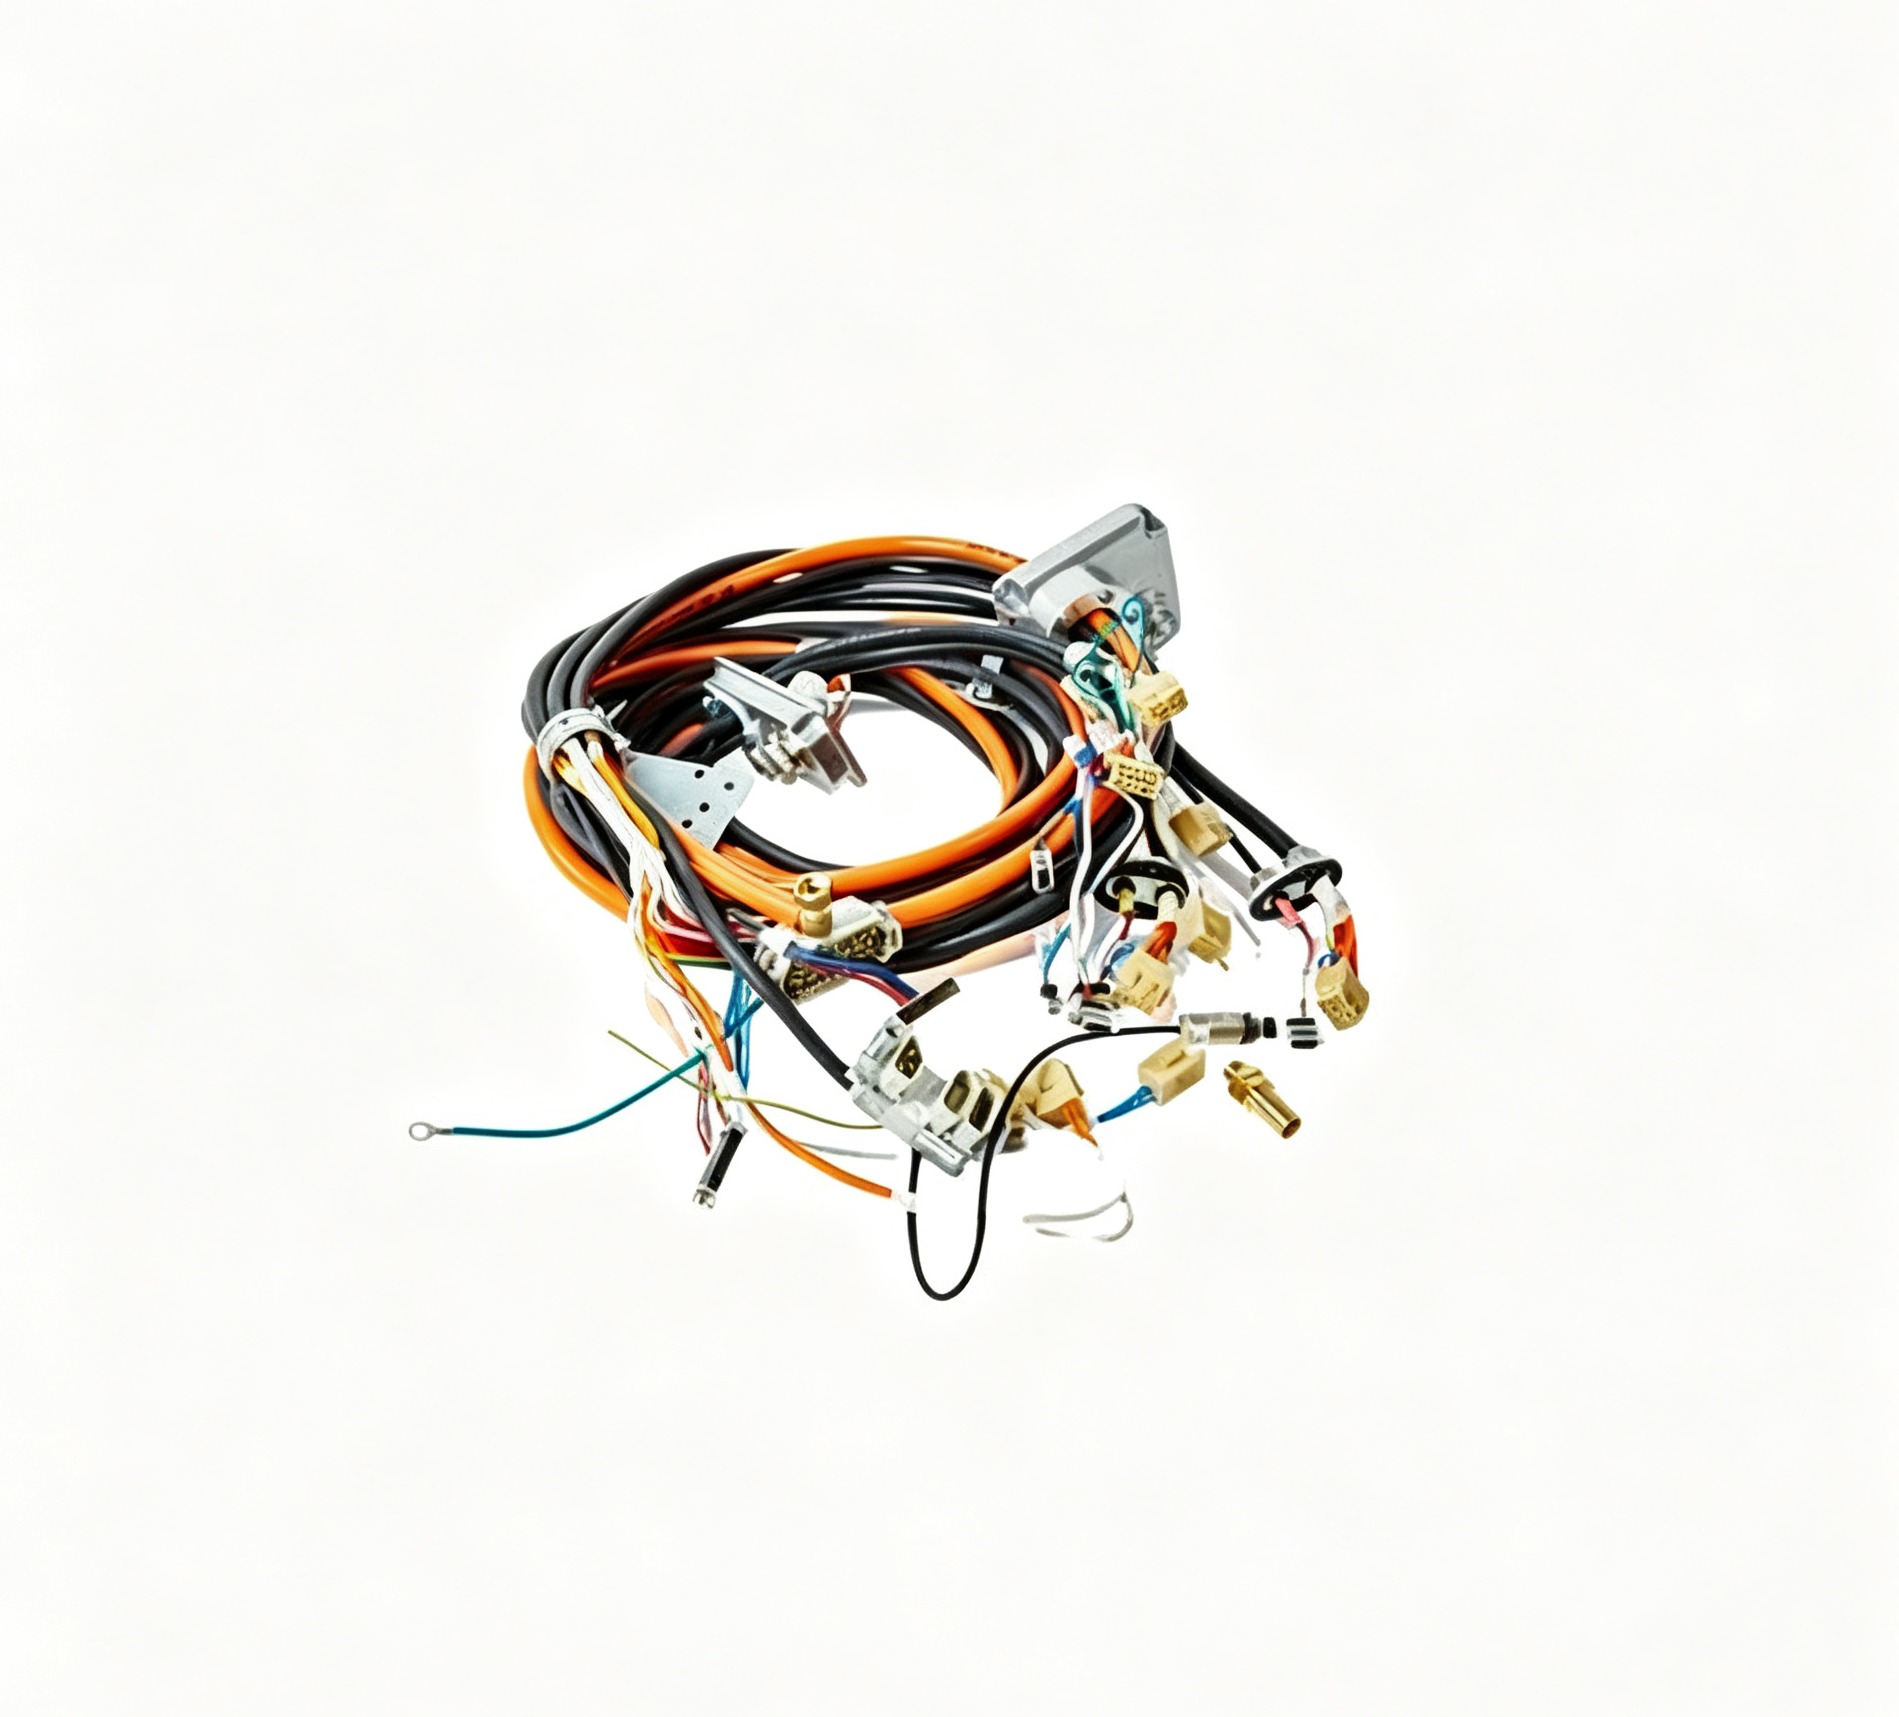
ABB 3HAC043206-001 Cable Harness Multibus
The ABB 3HAC043206-001 is identified as a Cable Harness, Multibus used in ABB industrial robot systems.
As part of a robot cable arrangement, the harness provides an organized electrical connection path between
system components associated with the Multibus configuration. Cable harnesses are an important part of an
industrial robot because they carry electrical and communication connections through a mechanically active
environment while maintaining an organized routing structure.
In ABB robotic equipment, cable assemblies are designed around the mechanical configuration of the manipulator
and the electrical architecture of the robot system. The 3HAC043206-001 part number is associated with ABB
Multibus harness configurations and is listed in documentation related to the IRB 4600 robot family.
Understanding the exact part number is therefore important when identifying a compatible harness for an
existing robot installation.
Product Identification
| Manufacturer | ABB |
|---|---|
| Part Number | 3HAC043206-001 |
| Product Name | Cable Harness, Multibus |
| Product Category | Industrial Robot Cable Harness |
| Application | ABB Industrial Robot Systems |
| Associated Robot Family | ABB IRB 4600 configurations |
Function of the ABB 3HAC043206-001
The primary purpose of a Multibus cable harness is to provide a structured connection between the relevant
electrical interfaces of an industrial robot system. Unlike a single-purpose cable, a harness can incorporate
multiple conductors or connection paths within an organized assembly. This arrangement helps maintain the
relationship between different signals and system interfaces throughout the robot installation.
In a robotic application, cable routing must accommodate both electrical requirements and the physical movement
of the manipulator. The robot continuously moves through programmed positions, so cables installed around the
manipulator must follow the intended routing path and avoid unnecessary interference with moving mechanical
parts. A dedicated harness therefore forms an important part of the overall robot architecture.
Multibus Configuration in ABB Robot Systems
The term Multibus refers to a bus-oriented communication and connection arrangement used within compatible ABB
robot configurations. The harness provides the physical cable structure required for the corresponding system
arrangement. Its role should be considered together with the robot controller, manipulator cabling, signal
connections, and other harness assemblies specified for the particular robot configuration.
ABB robot systems can contain several different cable harness assemblies, each designed for a specific
connection function. For this reason, visually similar cables should not automatically be considered
interchangeable. The part number, robot model, cable configuration, connector arrangement, and applicable
technical documentation should be checked before selecting a replacement component.
Relationship to ABB IRB 4600
ABB documentation for the IRB 4600 identifies Multibus cable harness assemblies as part of the robot’s cable
architecture. The 3HAC043206-001 part number appears in documentation associated with the Multibus arrangement.
The same documentation also distinguishes between earlier and later Multibus harness configurations, which is
important when identifying parts for different robot revisions.
In particular, ABB technical documentation records that 3HAC062246-001 replaced the earlier 3HAC043206-001
designation in a later revision. This means that part-number research should not rely only on the visible cable
appearance. When servicing an existing IRB 4600 installation, the robot revision, electrical configuration,
and applicable circuit documentation should be reviewed together.
Cable Routing and Mechanical Considerations
Cable routing is especially important in articulated robots because the harness is exposed to repeated movement
during normal operation. The cable should follow the intended routing arrangement defined for the corresponding
robot configuration. Excessive bending, contact with moving structures, incorrect fastening, or an unsuitable
routing path can place unnecessary mechanical stress on the cable assembly.
During maintenance, technicians should pay attention to the condition of cable jackets, connector areas,
fastening points, protective sections, and routing positions. Any unusual deformation, abrasion, cracking, or
loose connection can indicate that the cable path requires further inspection. The correct routing arrangement
should be maintained after service work so that the harness continues to move with the robot as intended.
Installation and Maintenance Considerations
Installation of the ABB 3HAC043206-001 should be performed with reference to the applicable ABB robot
documentation for the specific machine configuration. Before working on the cable harness, the robot system
should be placed in an appropriate maintenance state and all relevant electrical safety procedures should be
followed.
Connector identification is another important part of installation. A cable harness can contain multiple
connection points, and incorrect connection can affect communication, signal transmission, or other robot
functions. The part number alone should therefore be used as the starting point for identification rather than
as the only installation reference.
Routine inspection can help identify cable-related problems before they develop into larger system issues.
Maintenance personnel can inspect the harness for visible wear, mechanical damage, connector displacement, and
abnormal routing. If a fault is suspected, the relevant electrical diagrams and robot system documentation
should be consulted to determine the correct troubleshooting procedure.
Application in Industrial Automation
ABB robot cable harnesses are used in industrial automation environments where robotic manipulators perform
repeated and coordinated movements. Typical applications of ABB robot systems include material handling,
assembly, machine tending, welding, packaging, and other automated production processes. Within these systems,
cable assemblies provide the physical connection infrastructure required by the robot’s electrical and
communication architecture.
The 3HAC043206-001 Multibus cable harness can therefore be considered a system-level robot component rather
than an independent control device. Its function depends on the architecture of the associated robot and
controller. Correct identification is particularly important when maintaining older robot installations,
upgrading components, or comparing different revisions of the same robot configuration.
Part Number Verification
Before selecting ABB 3HAC043206-001 for a specific application, users should verify the complete part number
against the robot’s documentation and configuration information. Important references include the robot model,
electrical circuit diagram, harness designation, revision information, connector configuration, and any
documented replacement part.
This verification process is particularly useful because ABB robot systems may contain several harnesses with
similar physical characteristics but different electrical functions. A correct part-number match helps reduce
the possibility of selecting a cable assembly that does not correspond to the intended Multibus configuration.
Technical Summary
ABB 3HAC043206-001 is a Cable Harness, Multibus associated with ABB industrial robot systems and documented
in connection with ABB IRB 4600 configurations. The harness provides an organized cable connection structure
for the corresponding Multibus arrangement and forms part of the robot’s broader electrical architecture.
When working with this part number, the most important considerations are correct robot-model identification,
configuration compatibility, connector arrangement, cable routing, and applicable ABB documentation. Because
later ABB documentation identifies 3HAC062246-001 as a successor to 3HAC043206-001, users working with different
IRB 4600 revisions should verify the applicable harness designation before installation.
ABB 3HAC043206-001 should be identified by its complete part number and matched with the applicable robot
configuration and technical documentation. Part-number compatibility should be verified before installation,
particularly when working with different revisions of an ABB IRB 4600 system.
评价
目前还没有评价