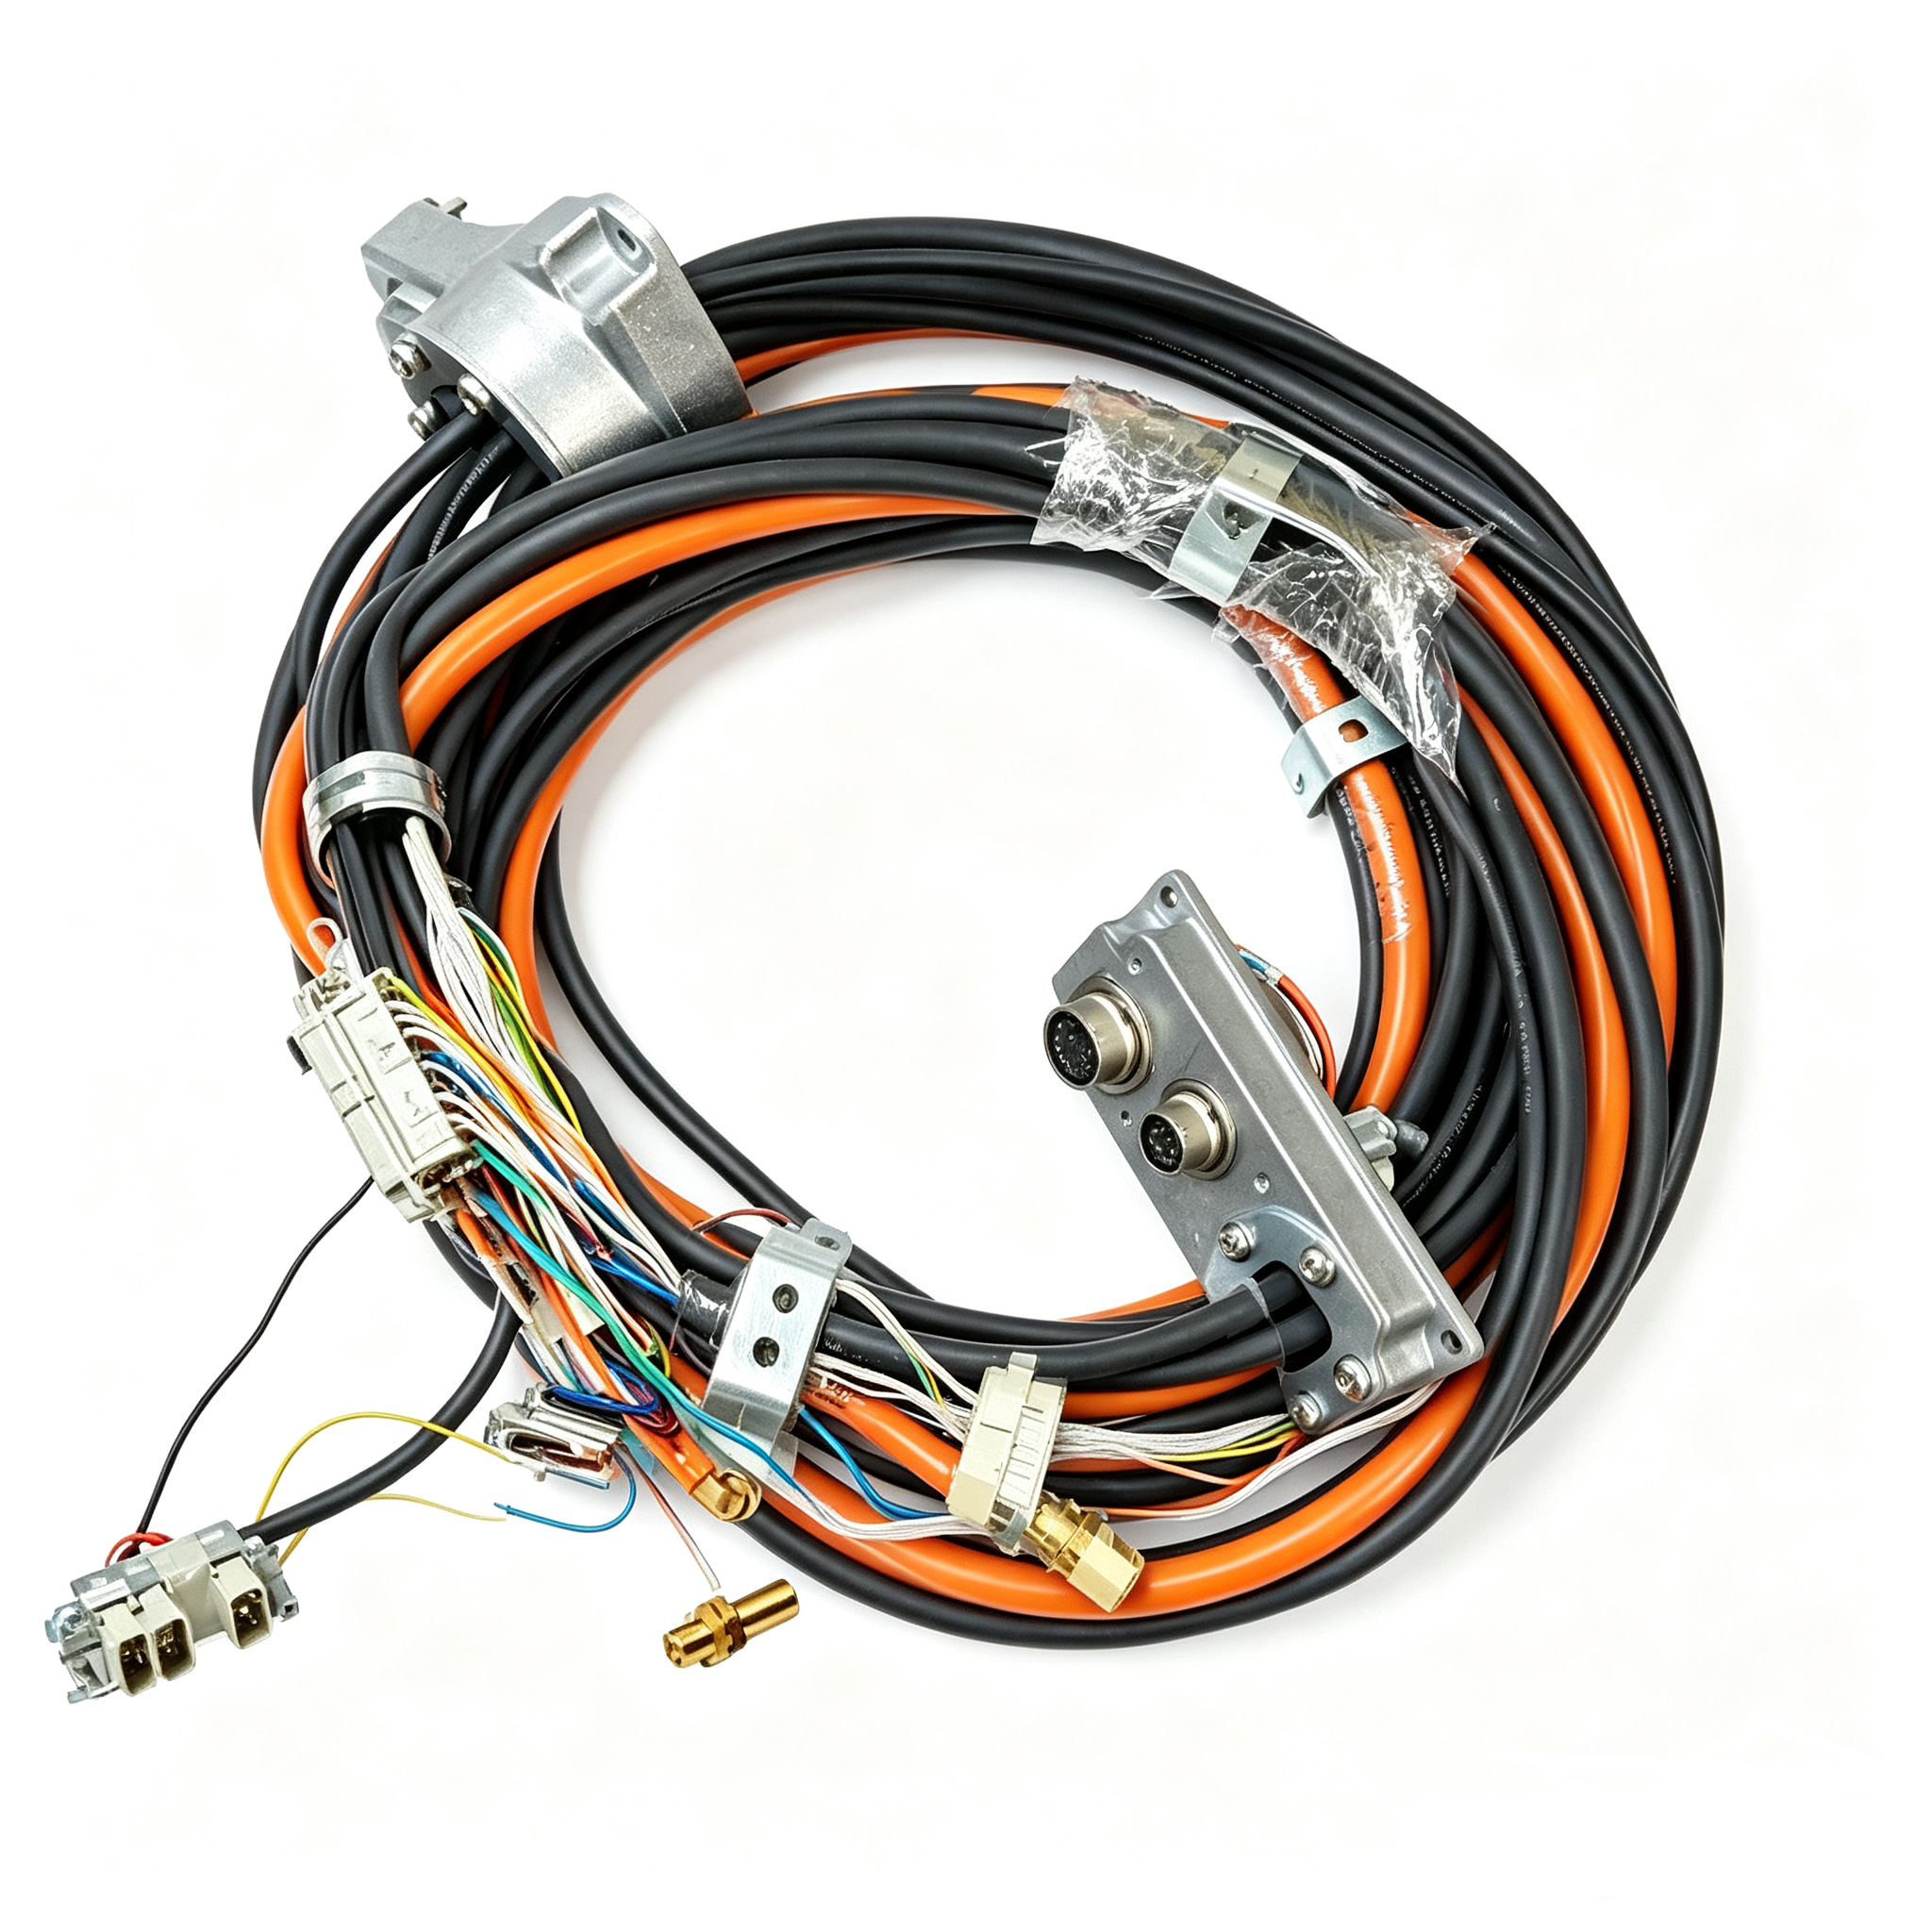
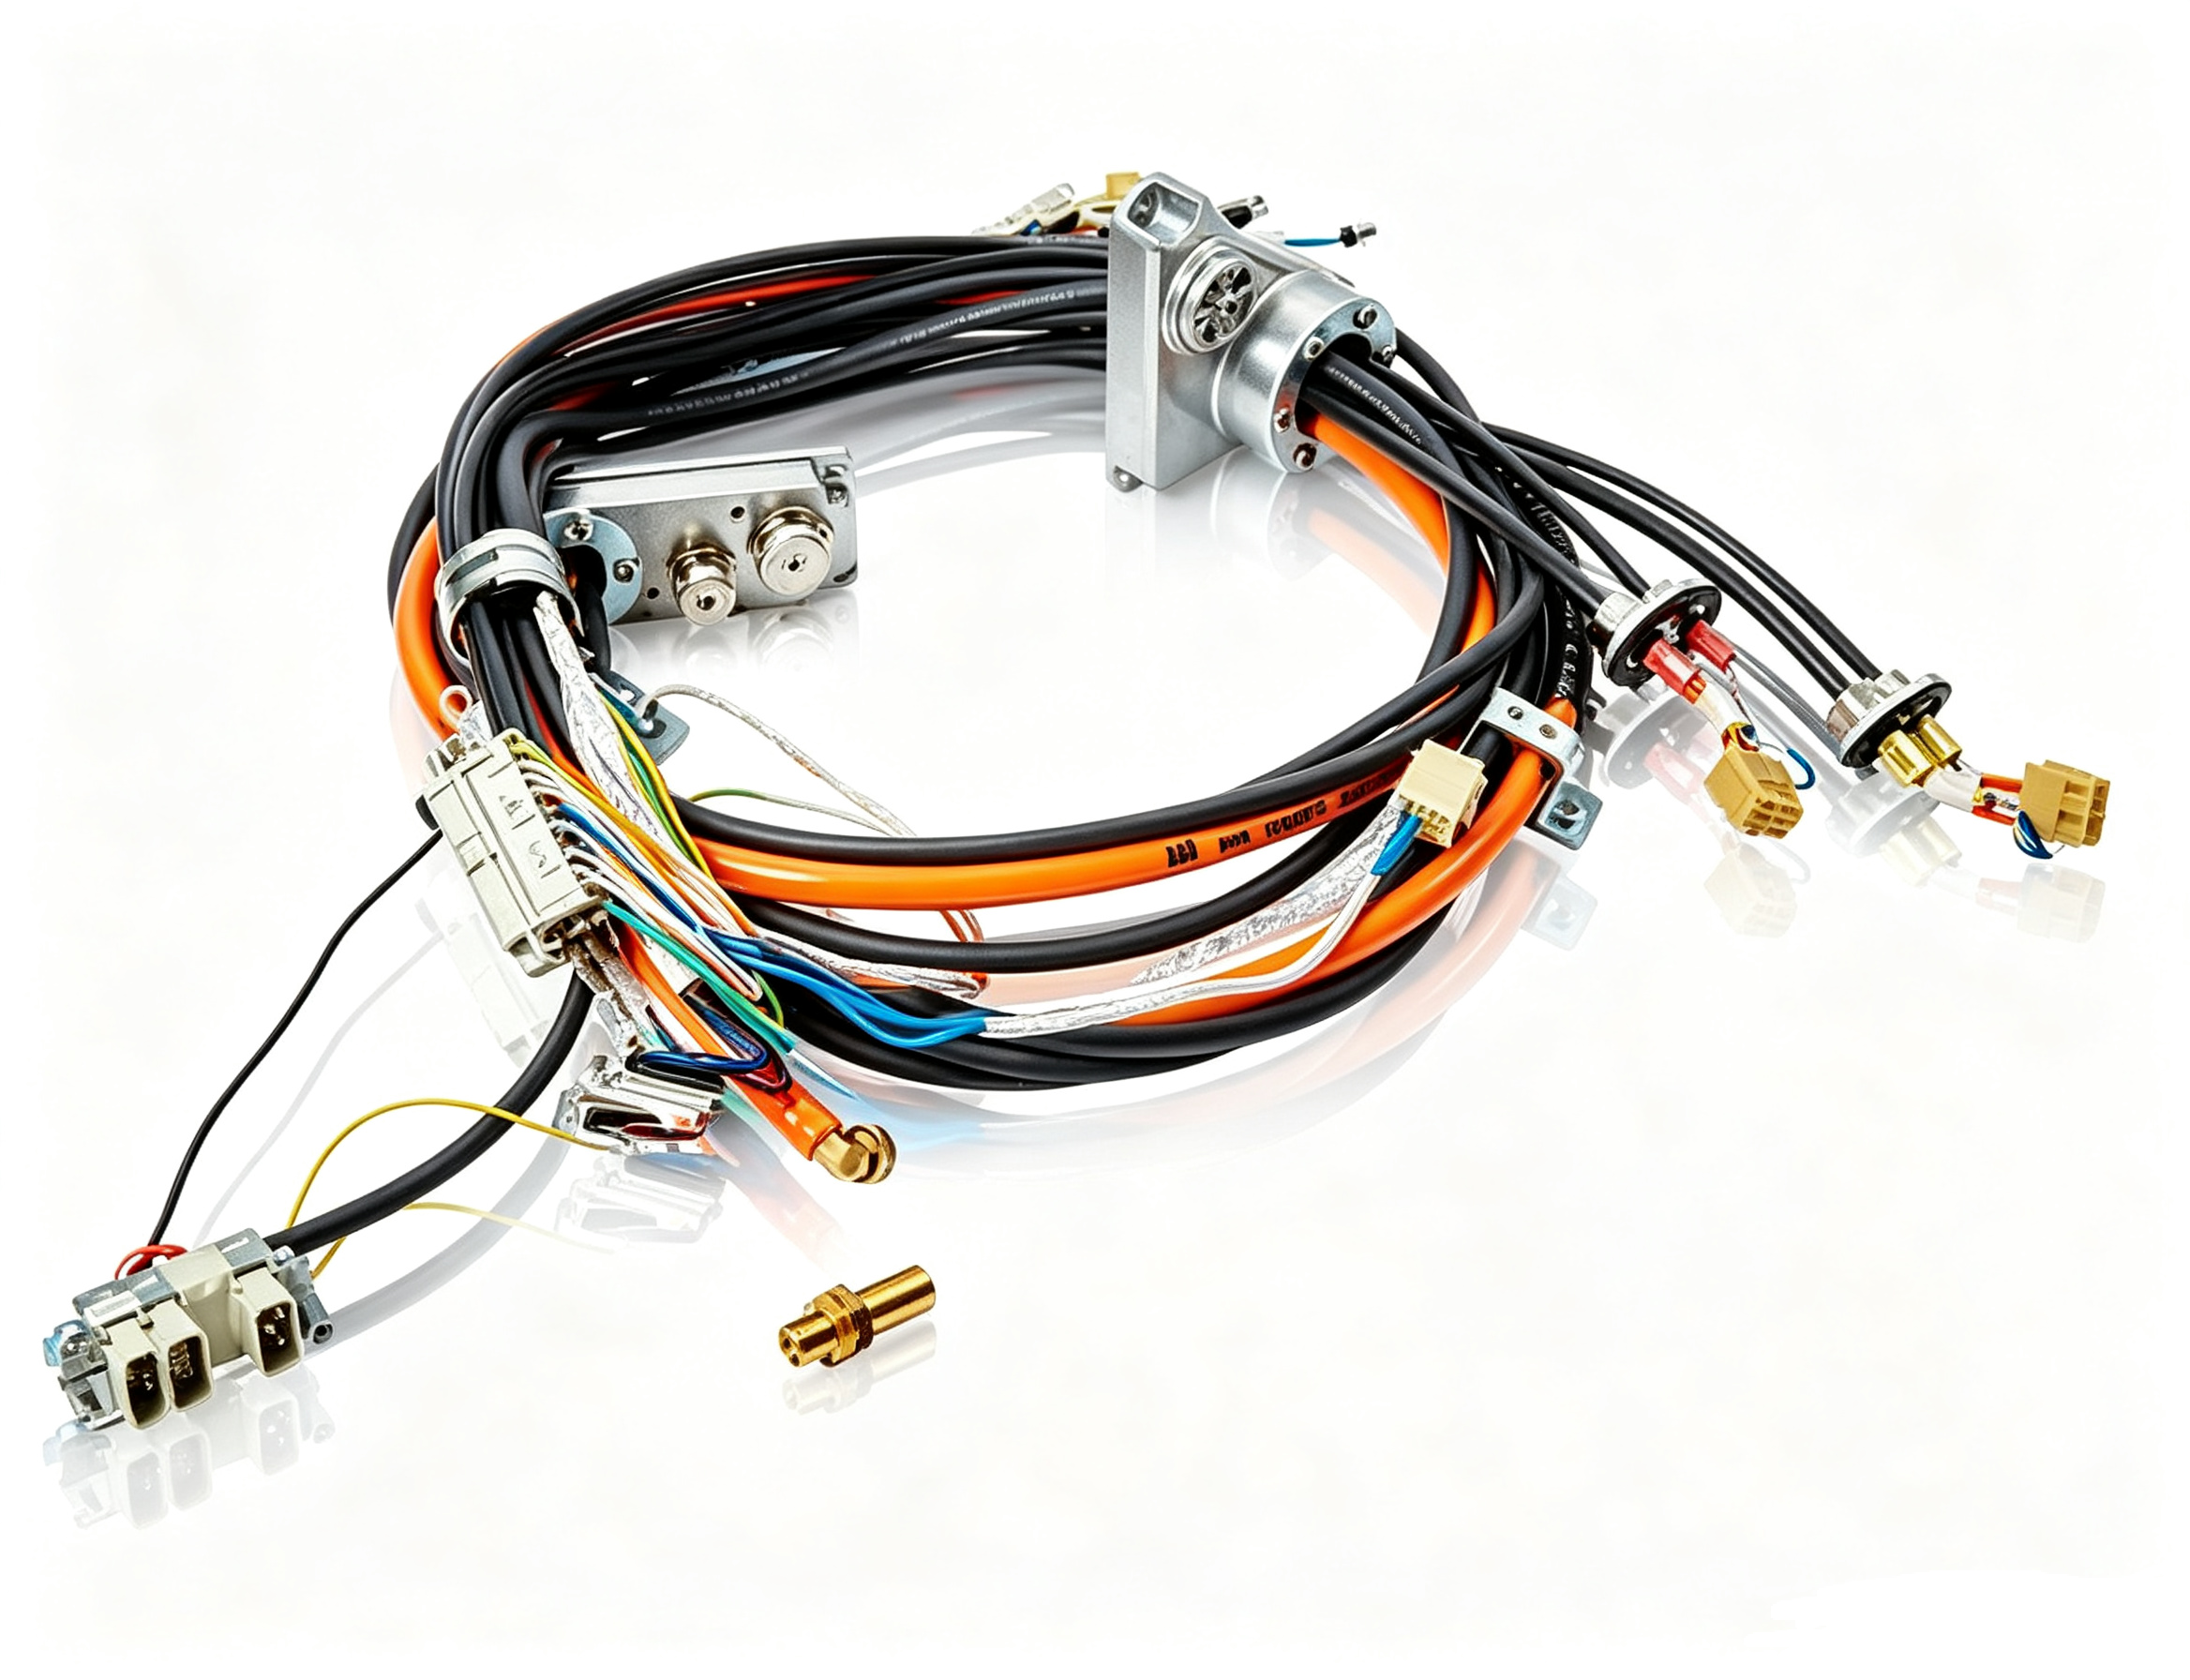
ABB 3HAC030007-001 Cable Harness Multibus
ABB 3HAC030007-001 is identified as a Cable Harness, Multibus used within ABB industrial robot
configurations. The component forms part of the cable and connection architecture of the robot
manipulator, providing an organized harness arrangement for the corresponding Multibus system.
In an industrial robot, cable assemblies are not simply passive wiring elements. Their routing,
connection points, mechanical arrangement, and relationship with the robot controller all have
an important role in maintaining the intended electrical architecture of the complete system.
ABB documentation for the IRB 2600 identifies 3HAC030007-001 as a Multibus cable harness.
The part is therefore closely associated with the electrical configuration of ABB IRB 2600
manipulators and their related controller architecture. Correct identification of the harness
is important because ABB robot systems can contain several cable assemblies with similar physical
characteristics but different electrical functions.
Product Identification
| Manufacturer | ABB |
|---|---|
| Part Number | 3HAC030007-001 |
| Product Name | Cable Harness, Multibus |
| Product Category | Industrial Robot Cable Harness |
| Associated Robot | ABB IRB 2600 |
| Control System | ABB IRC5 configurations |
Function of the ABB 3HAC030007-001
The main purpose of the ABB 3HAC030007-001 is to provide the physical cable connection structure
required by the Multibus arrangement of the applicable robot configuration. A cable harness groups
and organizes electrical connections so that the required signals and system interfaces can follow
an intended route through the manipulator.
Industrial robots operate through repeated movement of multiple mechanical axes. As the robot moves
through programmed positions, the associated cable harness must remain within the designated routing
area while accommodating the mechanical movement of the manipulator. The harness arrangement therefore
has to be considered as part of the overall robot design rather than as an independent cable installed
without reference to the mechanical structure.
Multibus Cable Harness Architecture
The term Multibus describes the connection arrangement associated with the relevant communication and
electrical architecture of the ABB robot system. The 3HAC030007-001 harness provides the cable assembly
associated with this arrangement in compatible configurations. Its function depends on the complete
robot system, including the manipulator, controller, connection points, and related electrical circuits.
The use of a dedicated harness allows the different connections to remain organized according to the
intended robot architecture. This is particularly important during service work because several cable
assemblies may be installed in the same robot. Identifying the correct part number helps distinguish the
Multibus harness from other assemblies such as basic cable harnesses, customer connection harnesses,
signal cables, or Profibus-related harnesses.
Application with ABB IRB 2600
ABB circuit documentation for the IRB 2600 lists 3HAC030007-001 among the valid cable harness assemblies
for the manipulator circuit. The same documentation distinguishes this Multibus harness from other
assemblies used by the robot, including the basic cable harness, customer connection harness, signal
cable, and other specialized cable configurations.
This distinction is important when servicing an IRB 2600 installation. A robot may contain multiple
harnesses serving different functions, and the physical appearance of one cable assembly may not be
sufficient to establish its electrical compatibility. The part number should therefore be considered
together with the robot model, electrical configuration, connector arrangement, and applicable circuit
documentation.
Cable Routing and Mechanical Requirements
Cable routing is a significant consideration in articulated robot applications. The manipulator performs
repeated movements around several axes, which means that cables are exposed to continuous mechanical
motion. The correct routing arrangement helps keep the harness away from unintended contact points and
allows the cable assembly to move with the robot structure according to its designed path.
During maintenance, the harness should be inspected for visible abrasion, deformation, damaged insulation,
connector problems, loose fastening points, or changes in its intended routing position. A cable that has
been displaced from its proper route may experience mechanical stress that was not present in the original
installation.
Particular attention should be given to areas where the cable passes near moving joints or mechanical
structures. The harness should not be forced into a routing position that conflicts with the robot’s normal
range of movement. After maintenance work, the cable arrangement should be returned to the configuration
specified for the relevant robot assembly.
Electrical Connection Considerations
The ABB 3HAC030007-001 should be treated as part of a defined electrical connection architecture.
Cable harnesses can carry multiple electrical or communication paths, and incorrect connection can
influence the operation of the associated robot functions. For this reason, connector identification
should be checked against the applicable ABB electrical documentation before installation.
When troubleshooting a robot system, cable-related faults can sometimes appear as communication errors,
intermittent signals, or unexpected system behavior. A systematic inspection of the cable harness,
connectors, routing path, and associated interfaces can help determine whether the problem originates
from the cable assembly or from another component in the robot system.
Maintenance and Service Considerations
Regular visual inspection of the cable harness can be useful as part of general robot maintenance.
Technicians can check the condition of the outer cable surface, connector areas, fastening locations,
and routing sections. Signs of repeated mechanical contact or abnormal movement should be investigated
before the robot is returned to normal operation.
If a harness needs to be removed or replaced, the technician should record the existing routing arrangement
and connector locations before beginning the work. The replacement cable should be installed according to
the applicable robot documentation rather than relying solely on the appearance of the removed assembly.
Electrical safety procedures should always be followed when working inside an industrial robot system.
The robot controller and manipulator should be placed in the appropriate maintenance state, and relevant
electrical isolation procedures should be followed before accessing cable connections.
Part Number Verification
Verification of ABB 3HAC030007-001 should begin with the complete part number. The identification should then
be compared with the robot model and the applicable electrical documentation. For an IRB 2600 installation,
the manipulator circuit diagram provides an important reference for identifying the Multibus harness and
distinguishing it from other cable assemblies.
Users should also consider the specific robot configuration and revision when selecting a cable harness.
ABB robot systems can evolve through different hardware and electrical configurations, and components that
appear similar may not necessarily provide the same connection arrangement. Checking the complete technical
documentation reduces the possibility of selecting an incompatible harness.
Role in Industrial Robot Systems
Cable harnesses are fundamental components in industrial robot systems because they provide the physical
connection infrastructure required between electrical and communication interfaces. A robot cannot operate
as an integrated automation system without correctly arranged connections between its mechanical assembly,
controller, sensors, motors, and related interfaces.
The ABB 3HAC030007-001 specifically belongs to the Multibus cable harness category. Its association with
the IRB 2600 makes it relevant to maintenance, repair, configuration identification, and service activities
involving compatible ABB robot installations. The component should be evaluated as part of the complete
robot architecture rather than independently of the associated manipulator and controller.
Technical Summary
ABB 3HAC030007-001 is a Cable Harness, Multibus identified for ABB industrial robot systems and documented
in connection with the IRB 2600 manipulator. It provides an organized cable assembly for the corresponding
Multibus arrangement and forms part of the robot’s electrical connection structure.
The most important points when identifying this component are the complete part number, robot model,
electrical configuration, connector arrangement, cable routing, and applicable ABB circuit documentation.
Because the IRB 2600 system can contain several different harness assemblies, correct part-number verification
is important before installation or replacement.
ABB 3HAC030007-001 should be matched with the applicable ABB robot configuration and electrical documentation.
For IRB 2600 applications, verify the complete harness designation, connector arrangement, and routing
requirements before installation.
评价
目前还没有评价