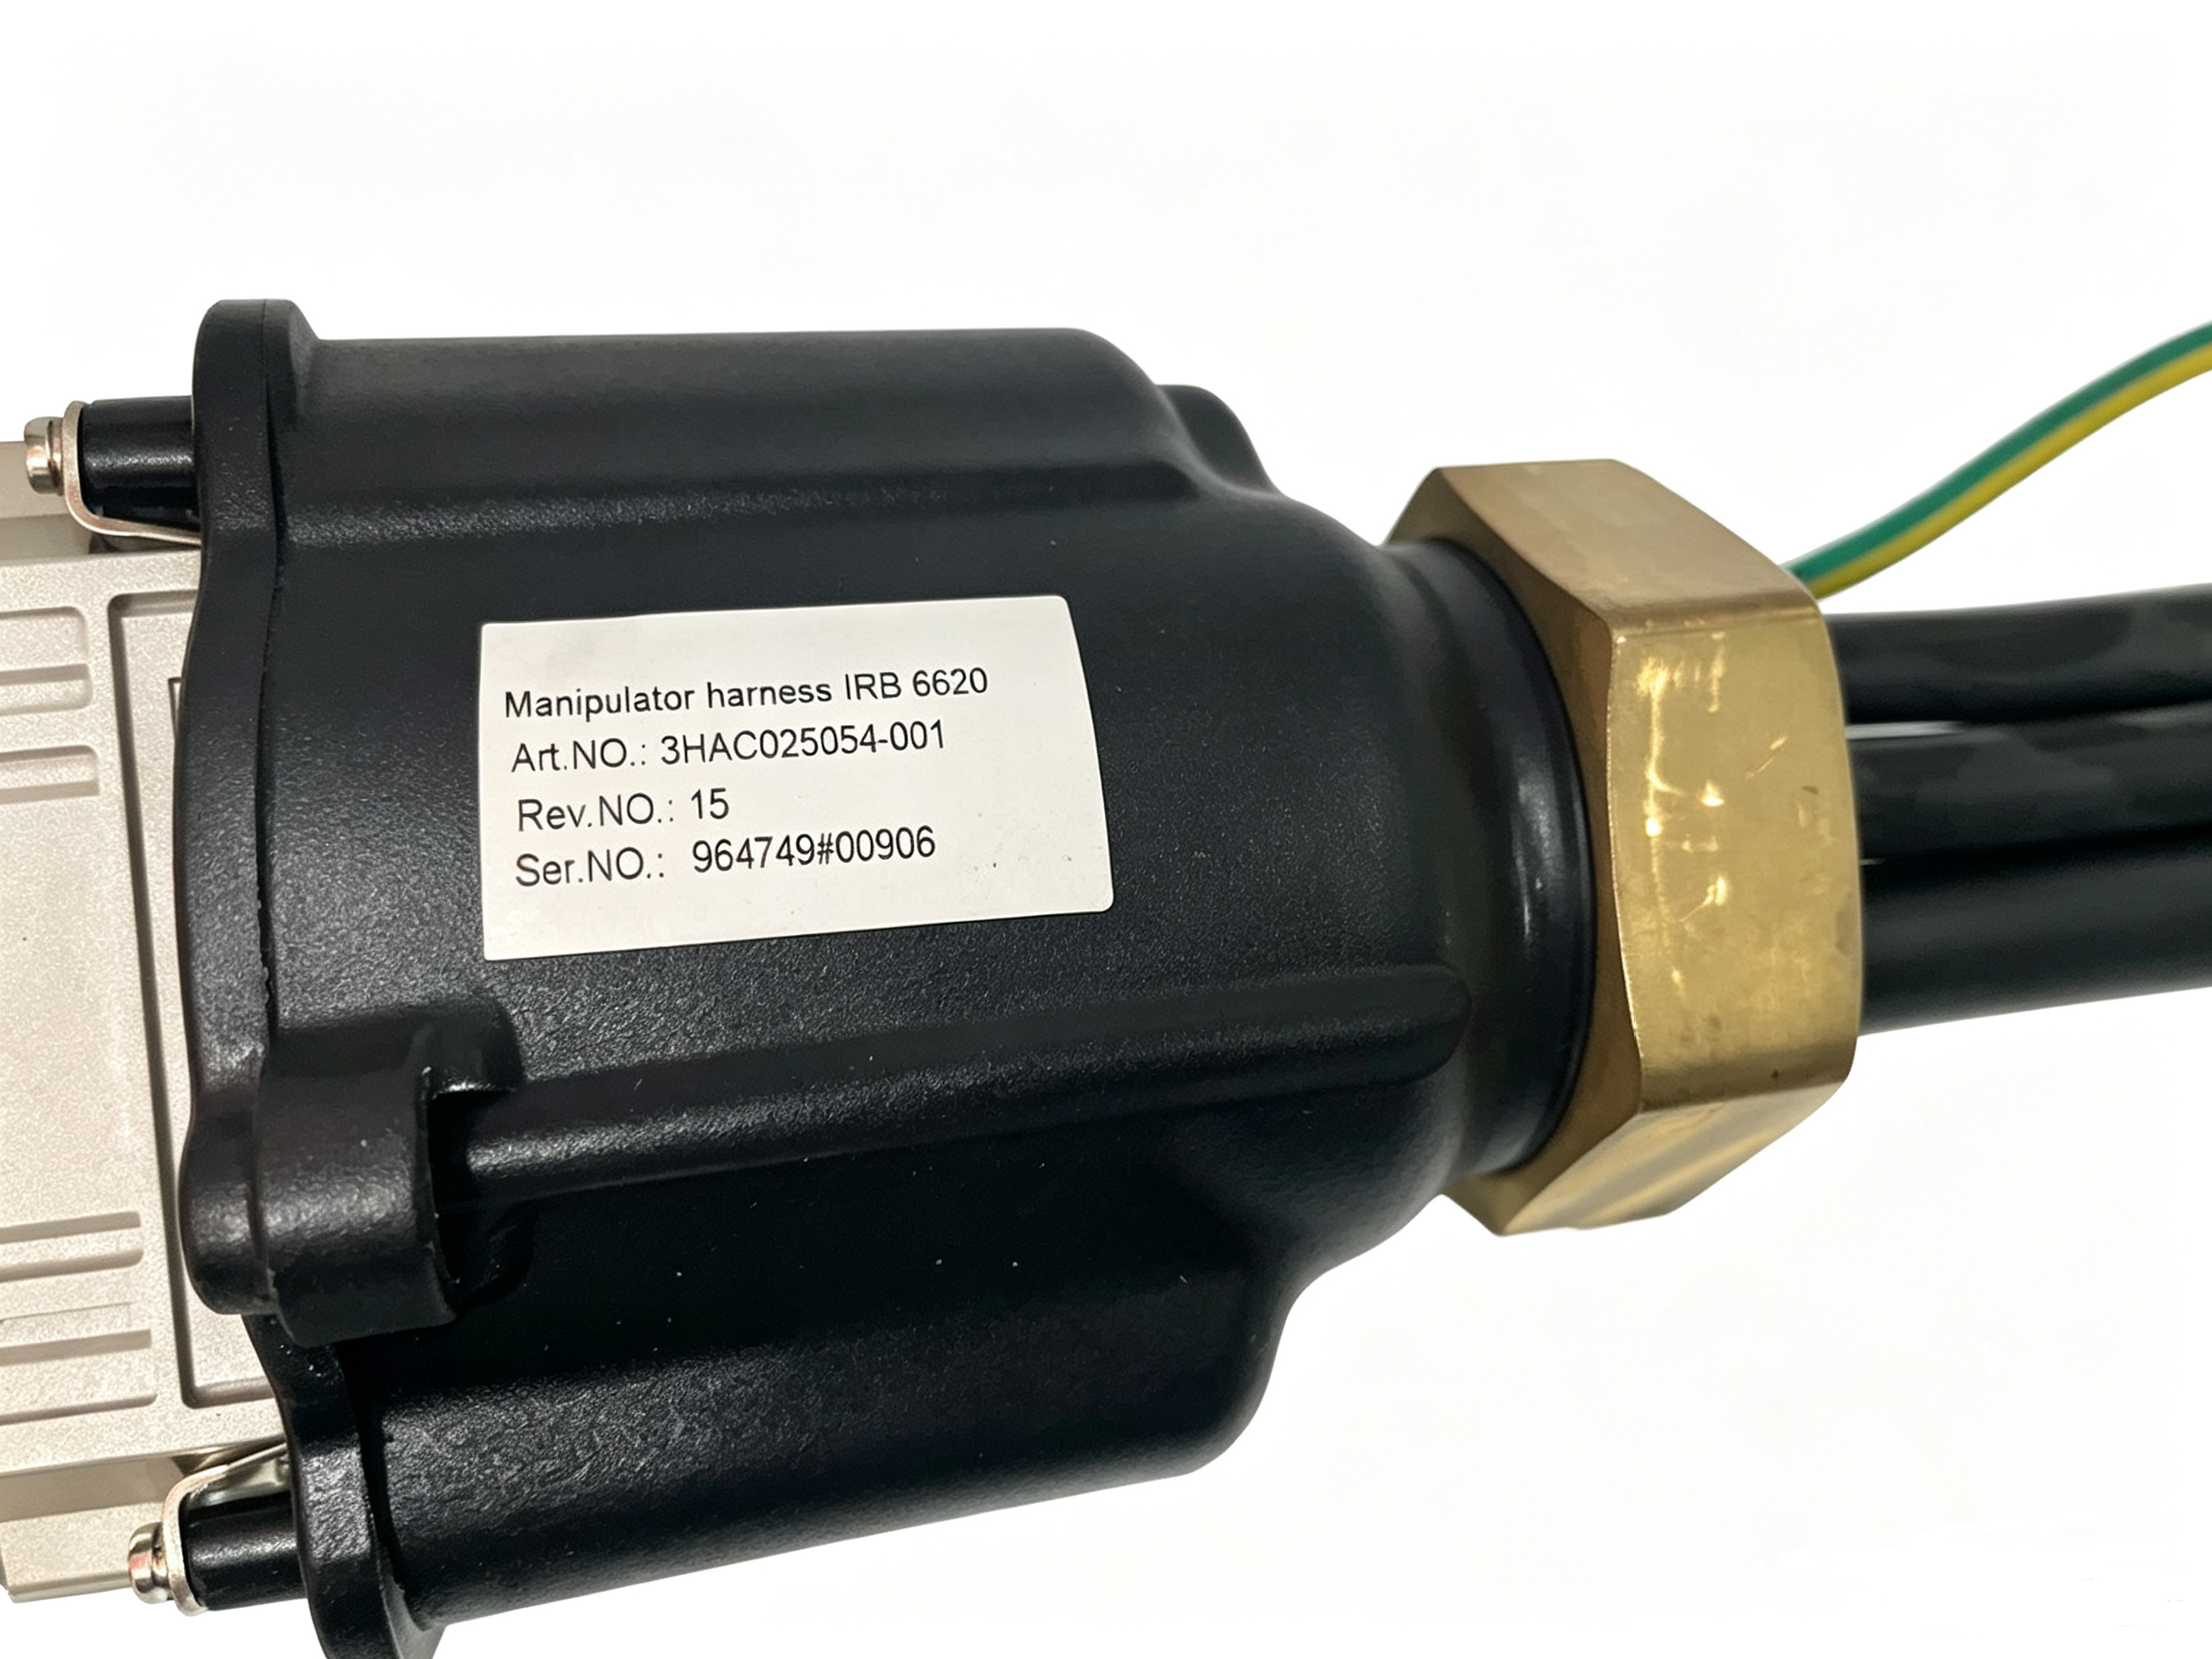
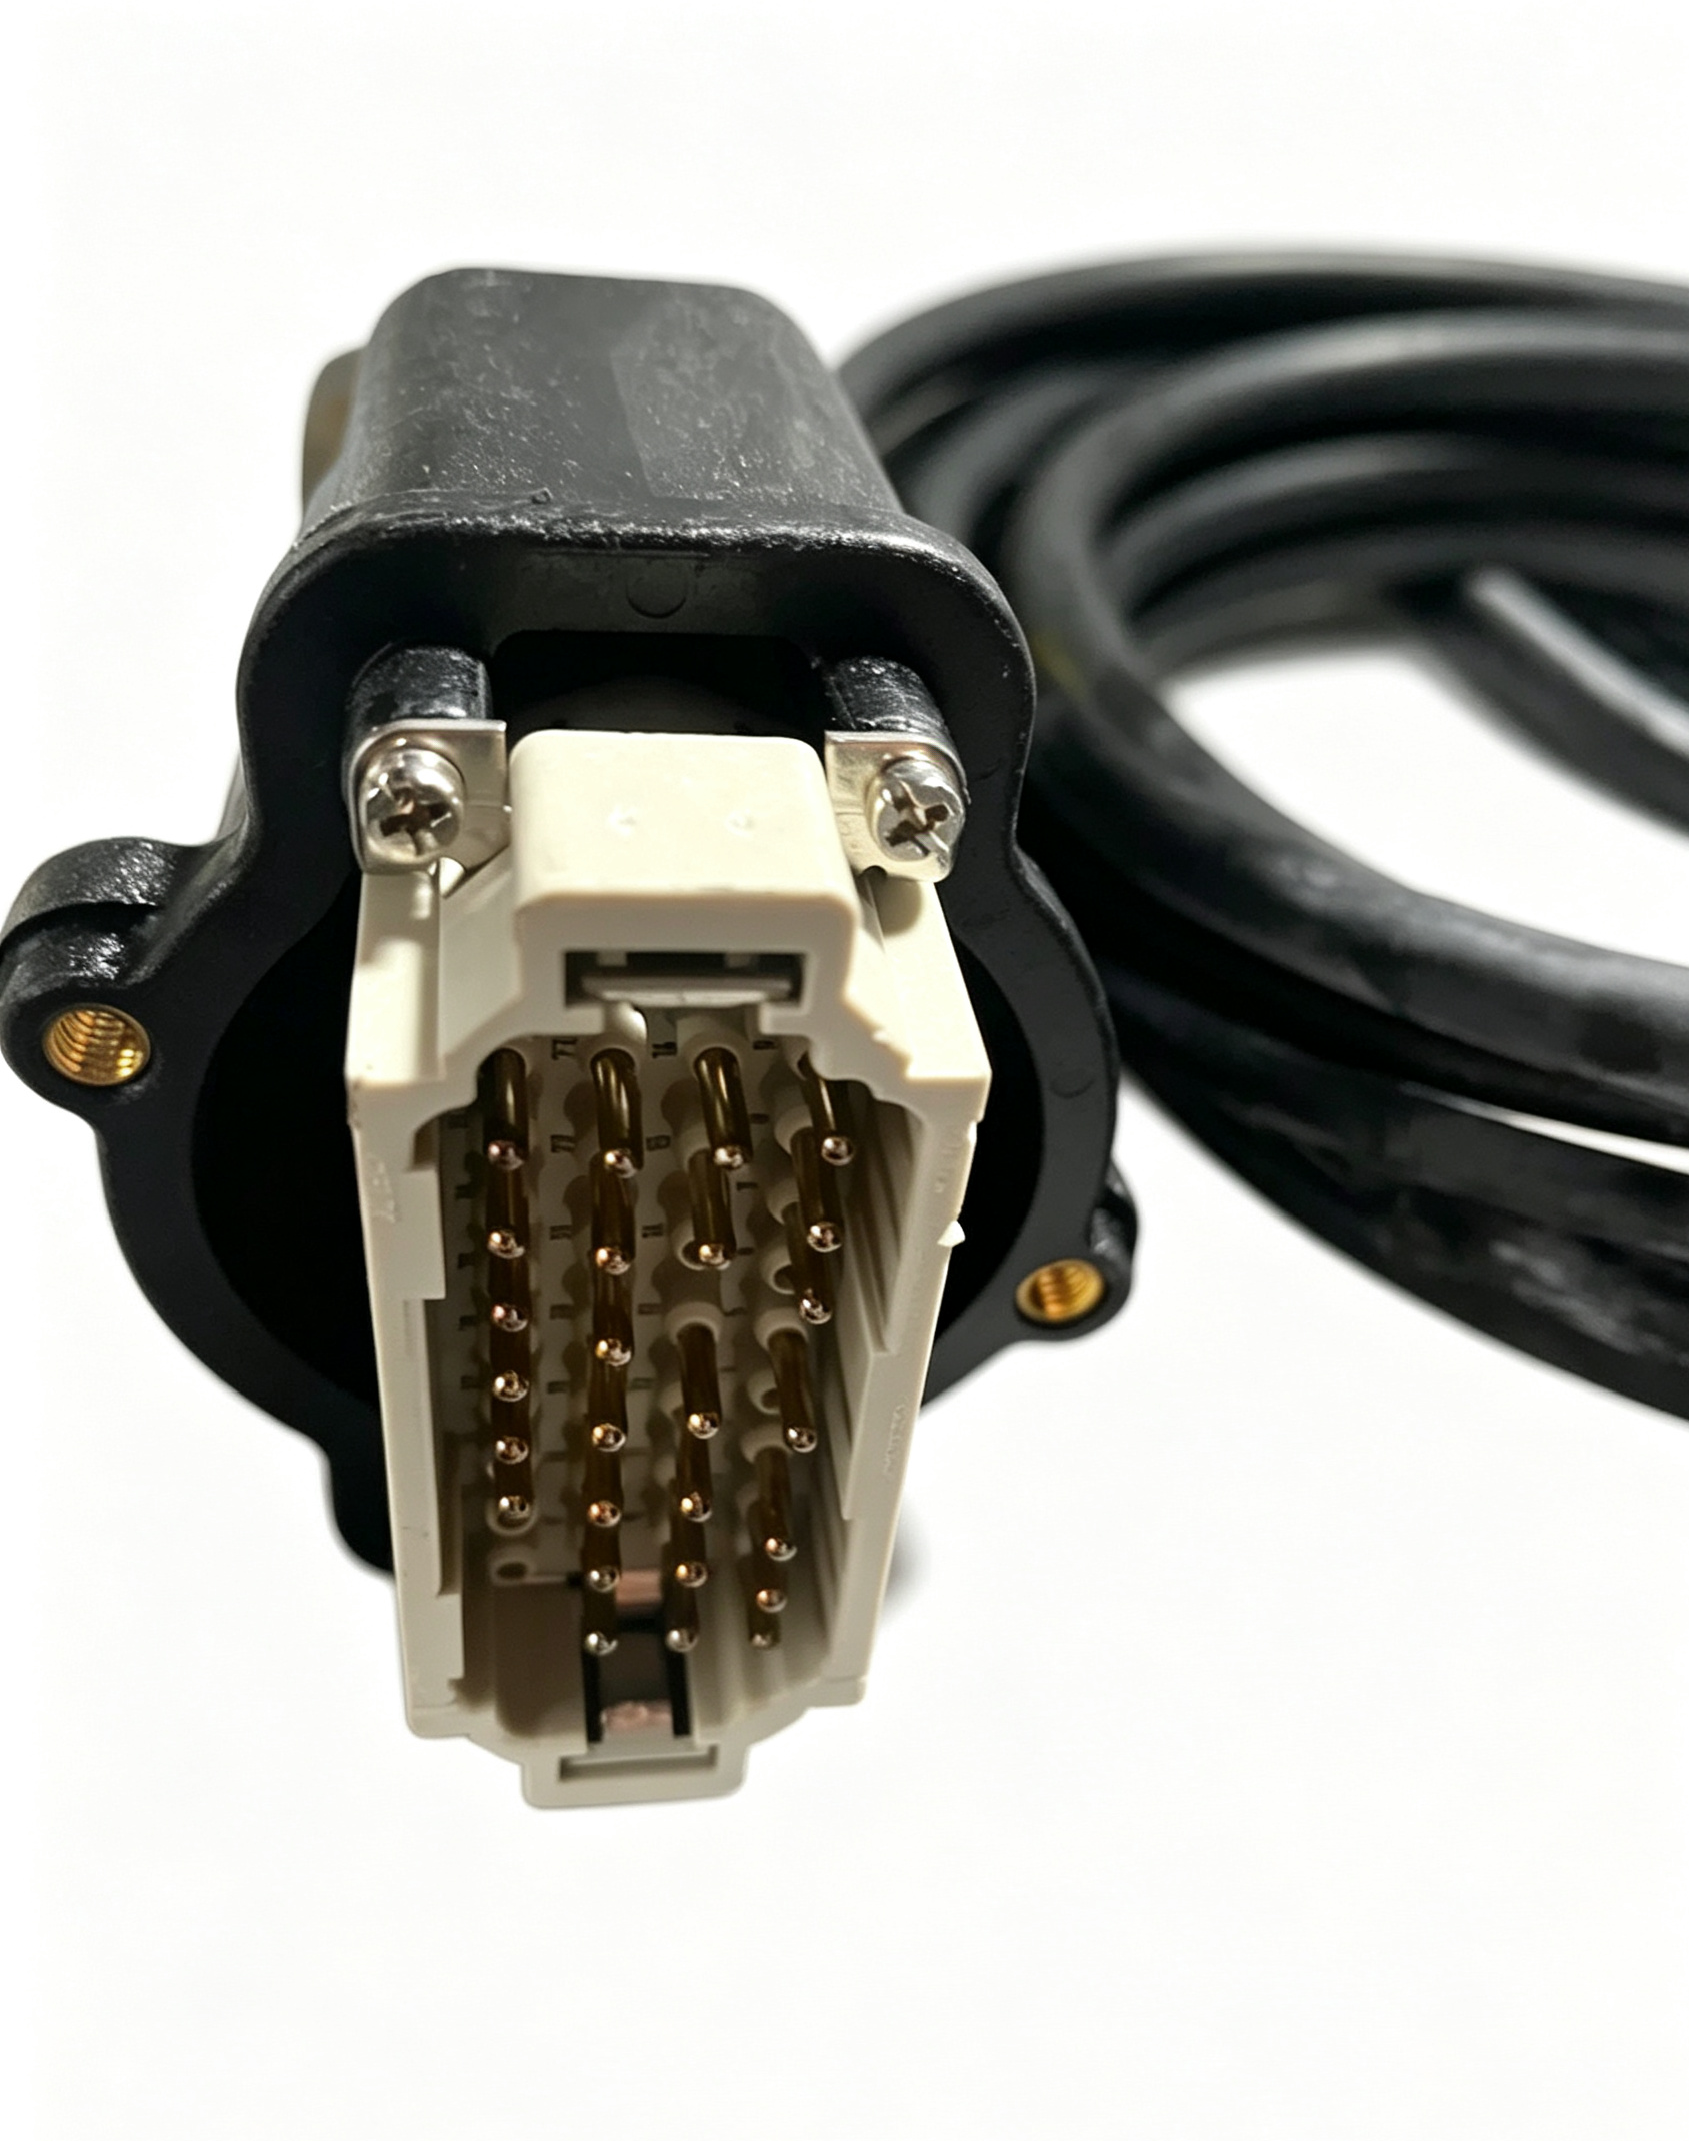
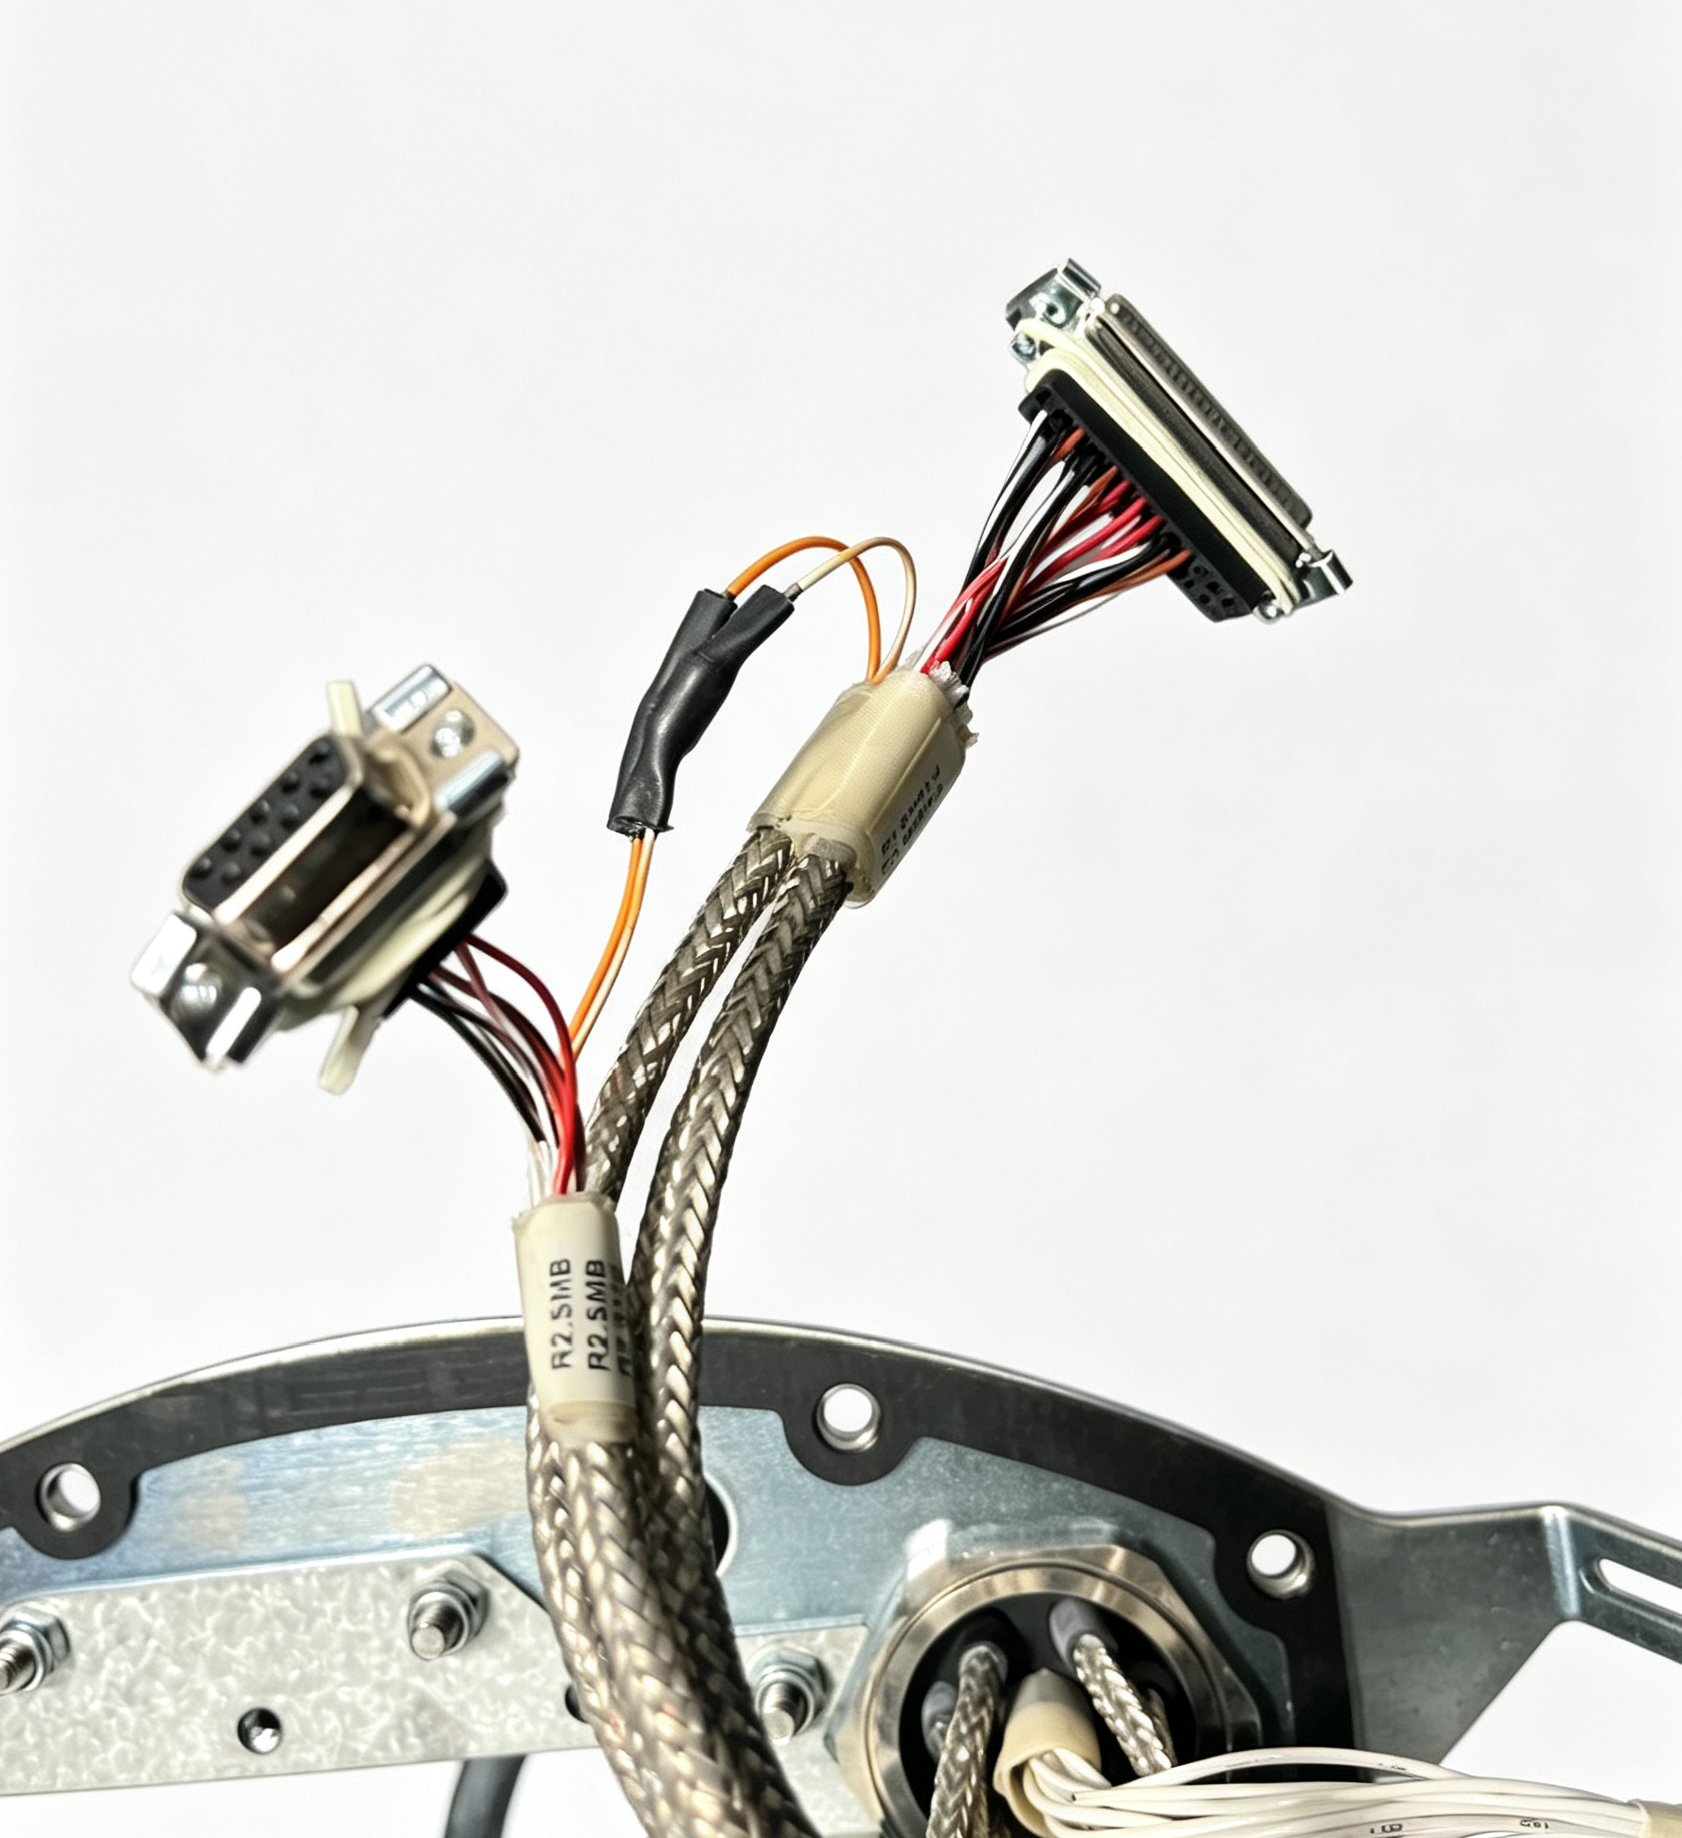
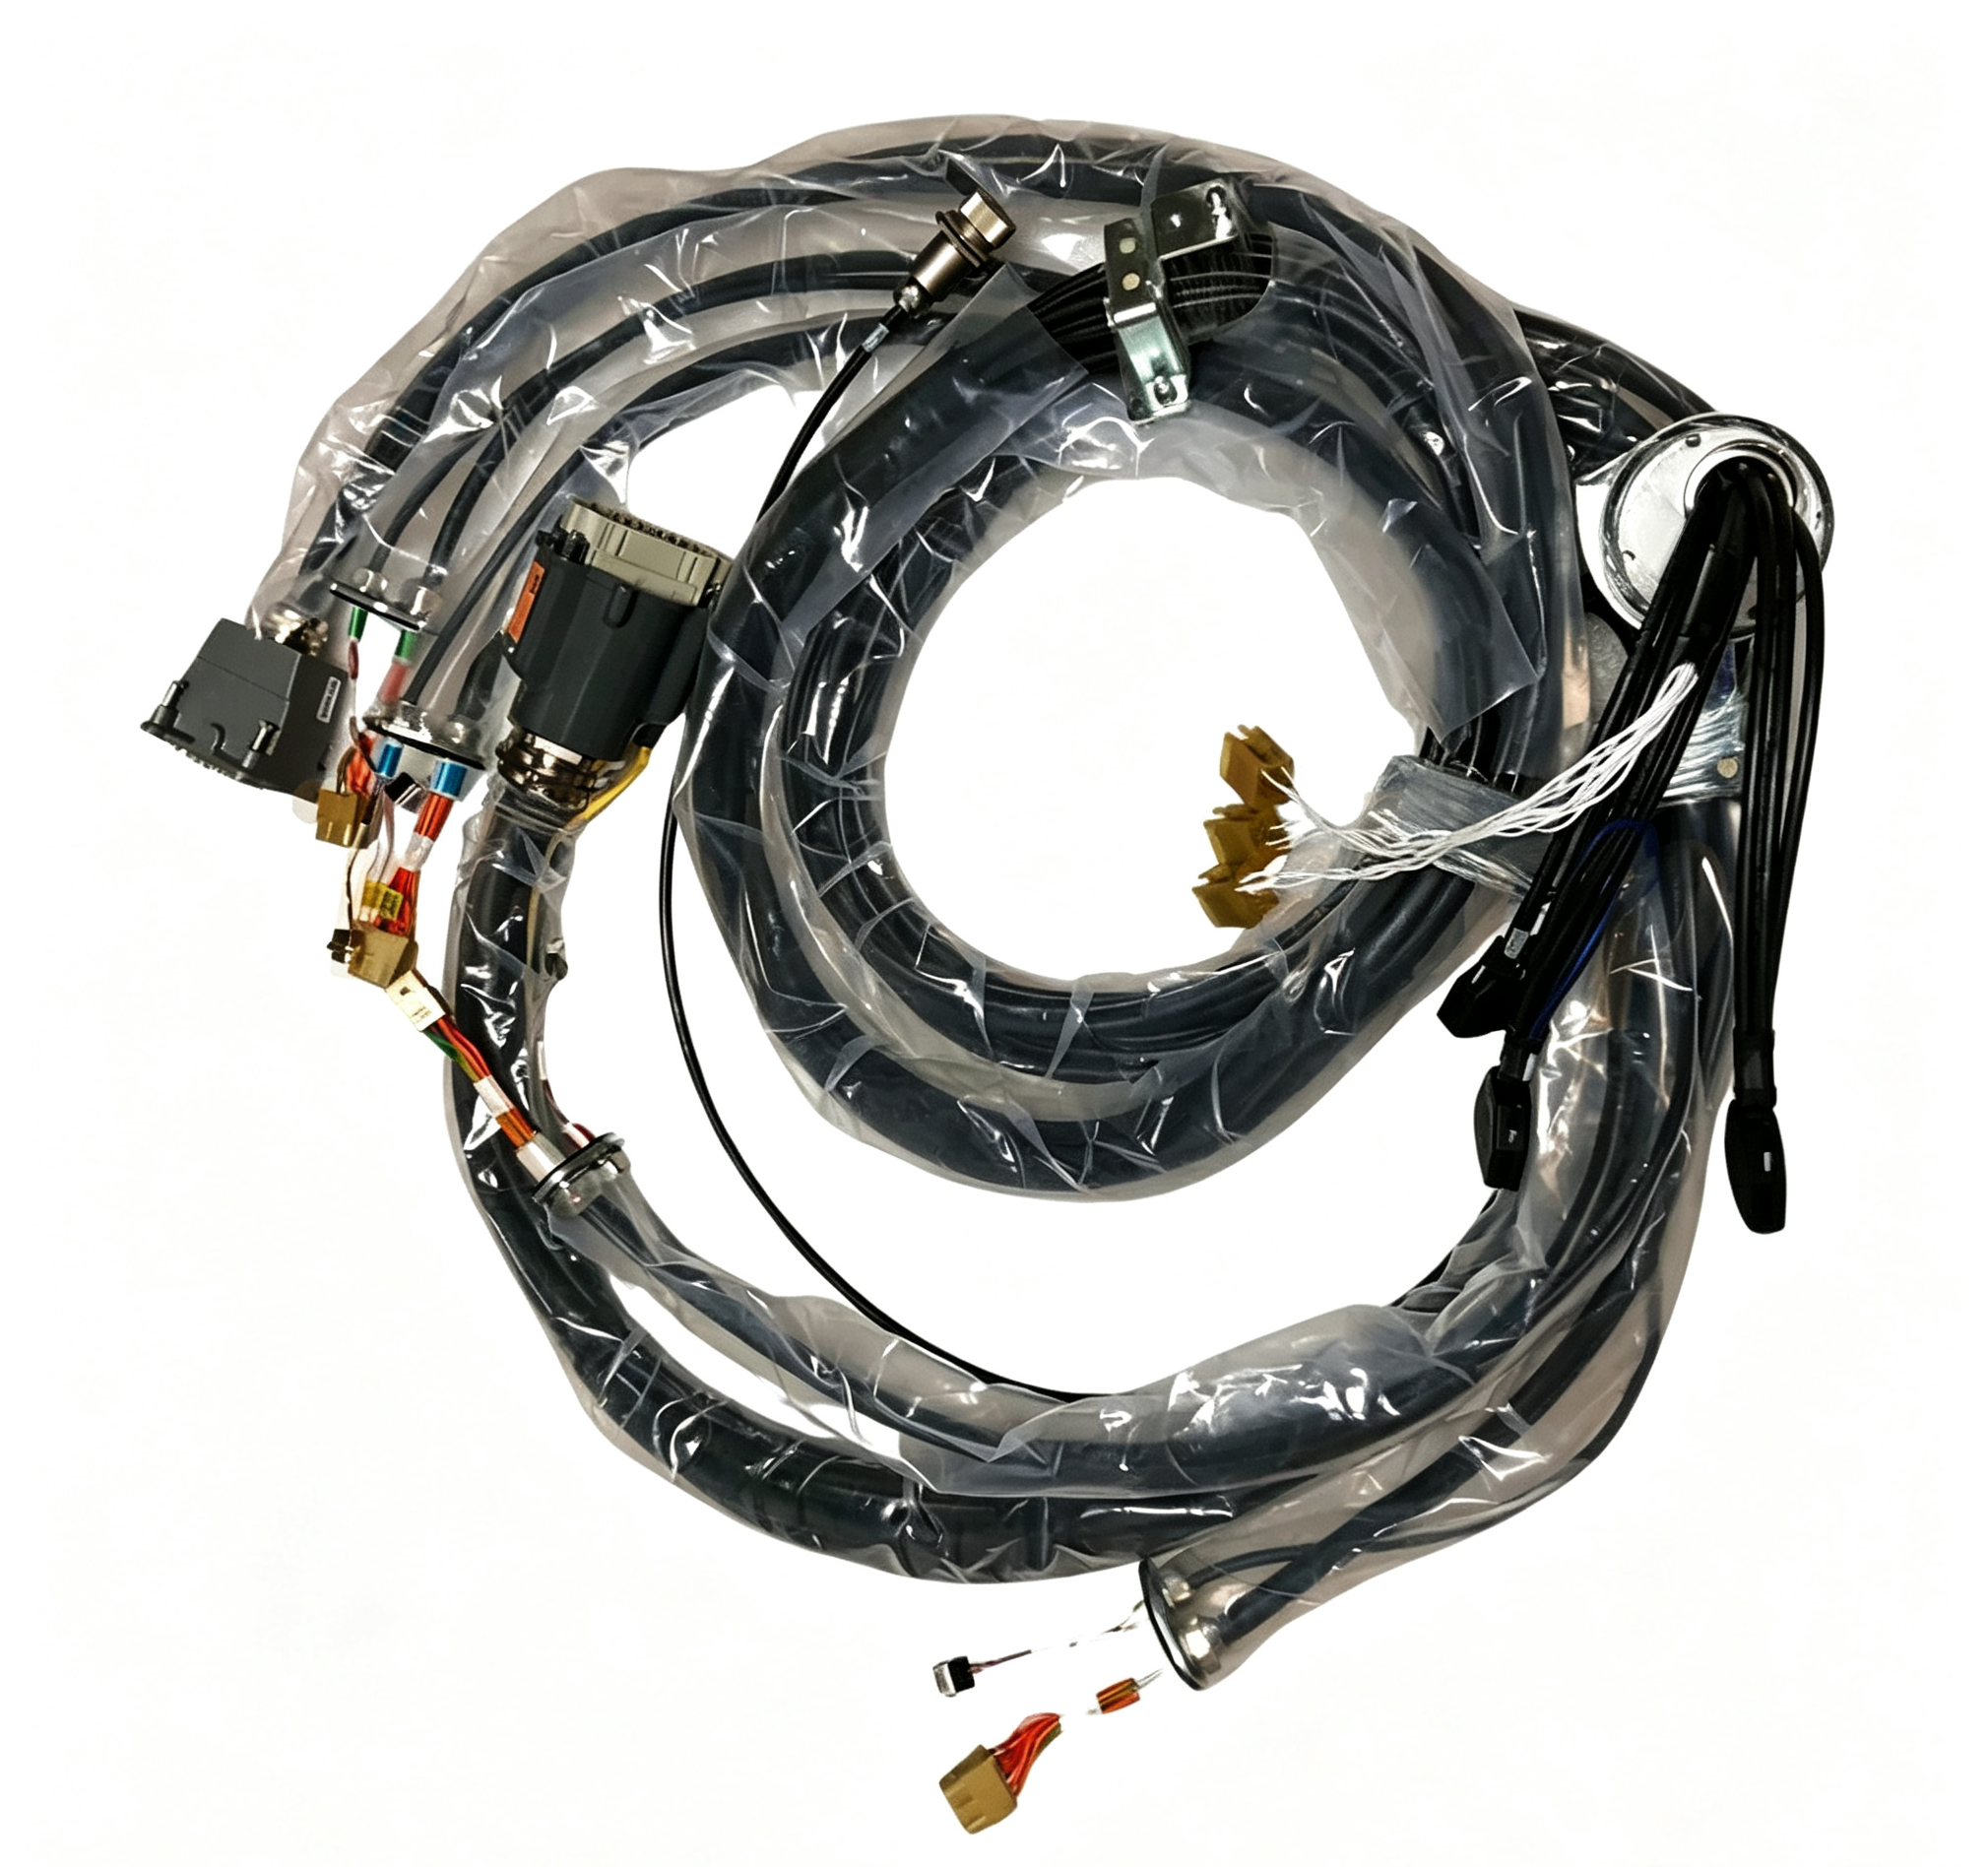
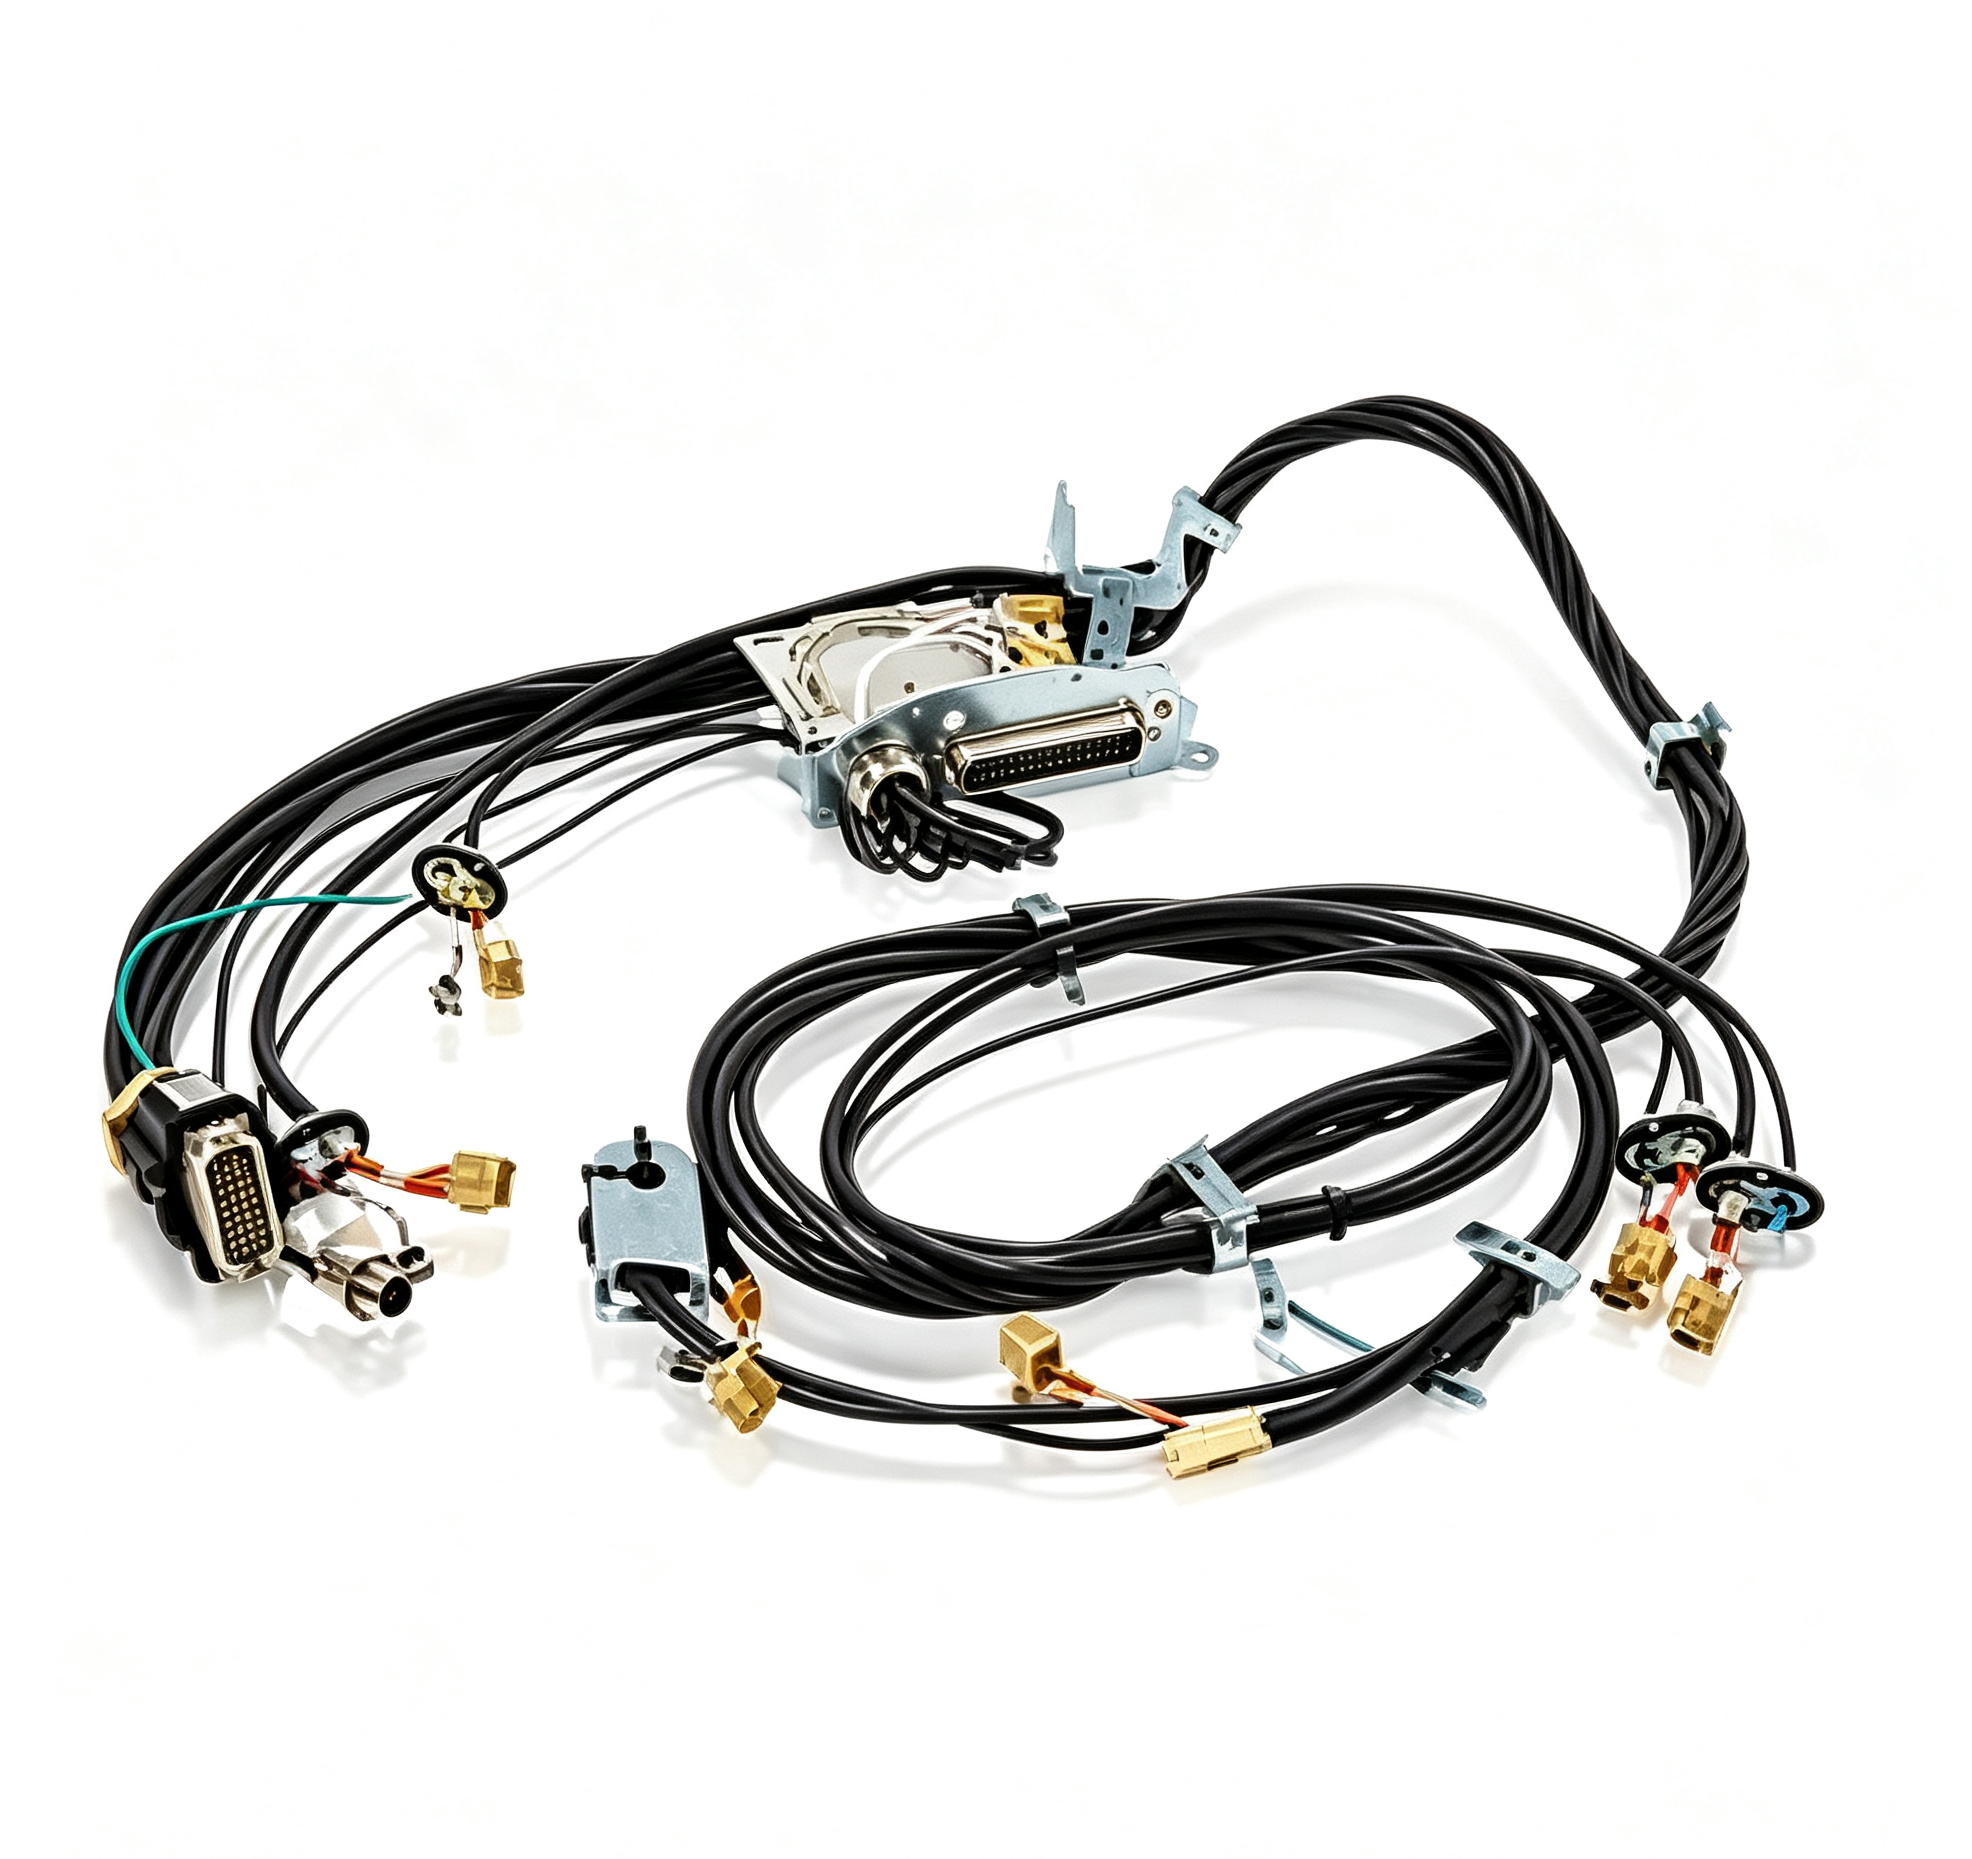
ABB 3HAC025054-001 Manipulator Harness for IRB 6620 Robot Axis 1–6
The component is identified as a Manipulator Harness Axis 1–6 and forms part of the internal
electrical cabling system of the robot manipulator. It provides the organized cable connections
required for communication, signals, and electrical circuits associated with the robot axes.
ABB 3HAC025054-001 Product Overview
ABB 3HAC025054-001 is a dedicated robot manipulator harness associated with the ABB IRB 6620
industrial robot platform. ABB spare-parts documentation identifies this part number as the
Manipulator Harness, while related technical documentation specifies its application
as the manipulator harness for axes 1–6.
The harness is an important part of the robot’s internal electrical architecture. Unlike a single
electronic board or controller module, a manipulator harness consists of interconnected wiring
assemblies that route electrical signals and power-related connections through the robot structure.
In a six-axis industrial robot, the cable system must accommodate the movement of multiple mechanical
joints while maintaining reliable electrical connections. The harness therefore has to be routed
appropriately through the manipulator and connected to the relevant motors, sensors, feedback devices,
and electrical interfaces.
Technical Specifications
| Manufacturer | ABB |
|---|---|
| Part Number | 3HAC025054-001 |
| Product Type | Manipulator Harness |
| Applicable Robot | ABB IRB 6620 |
| Axis Coverage | Axis 1–6 |
| Application | Industrial robot manipulator internal cabling |
| Component Category | ABB Robotics cable and harness assembly |
| Related Documentation | ABB IRB 6620 spare-parts and cable-harness documentation |
Function of the Manipulator Harness
The manipulator harness provides the electrical connection structure required inside the ABB IRB 6620
robot. A robot manipulator contains several electrically controlled systems, including axis motors,
position feedback components, sensors, and other electrical interfaces. The harness provides an organized
route for these circuits through the mechanical structure.
Because the IRB 6620 is a multi-axis articulated robot, the internal wiring must accommodate continuous
mechanical movement. The harness is therefore more than a collection of ordinary stationary wires.
Its installation and routing are directly related to the movement characteristics and mechanical
construction of the robot.
Correct harness routing helps prevent excessive bending, mechanical interference, abrasion, and
unnecessary tension. Maintaining the intended routing arrangement is particularly important around
moving joints, where cables are repeatedly exposed to changes in position during robot operation.
ABB IRB 6620 Compatibility
ABB documentation specifically identifies 3HAC025054-001 as the manipulator harness for the IRB 6620.
The same part number appears in IRB 6620 spare-parts documentation and related circuit documentation,
providing a strong reference for identifying the component within this robot family.
The IRB 6620 is an articulated industrial robot with six controlled axes. The designation
“Manipulator Harness Axis 1–6” indicates that this harness belongs to the robot-side electrical
connection system covering the six-axis manipulator.
It is important to distinguish this component from harnesses intended for other ABB robot models.
ABB uses different cable assemblies for different manipulators, mechanical configurations, revisions,
and application requirements. A similar-looking harness should not automatically be considered an
interchangeable component.
Internal Robot Cable Architecture
Industrial robot wiring must operate under conditions that are substantially different from ordinary
fixed control-panel wiring. The cable assembly is installed within a mechanical system that repeatedly
changes position, and individual sections of the harness can experience bending and movement during
normal robot operation.
The ABB 3HAC025054-001 harness is consequently part of the robot’s overall mechanical-electrical
integration. Its cable routing connects electrical functions across different areas of the manipulator
while following the physical structure of the robot.
Proper installation is important because cable routing can affect both electrical reliability and
mechanical movement. Excessive tension, incorrect routing, sharp bending, or contact with moving
mechanical components can accelerate cable deterioration and may eventually cause intermittent or
permanent electrical faults.
Applications
ABB 3HAC025054-001 is primarily associated with ABB IRB 6620 robotic equipment. The harness can be
relevant to maintenance, repair, cable replacement, robot refurbishment, and service operations involving
compatible IRB 6620 manipulators.
- ABB IRB 6620 industrial robots
- Manipulator axis 1–6 electrical connections
- Robot internal cable systems
- Industrial robotic manufacturing cells
- Automated material handling systems
- Robot maintenance and cable replacement
- ABB robotic equipment service applications
Importance of Correct Part Number Identification
Accurate part-number identification is essential when working with ABB robot harness assemblies.
The complete designation 3HAC025054-001 should be used when matching the component
with spare-parts documentation and robot configuration information.
ABB has produced numerous harness assemblies for different robot models and generations. Harnesses
can differ in cable length, connector arrangement, routing configuration, axis coverage, and electrical
interfaces. Therefore, selecting a component based only on its external appearance may lead to an
incorrect match.
When replacing the harness, maintenance personnel should verify the robot model, manipulator configuration,
part number, connector arrangement, and applicable documentation before installation.
Maintenance Considerations
Robot harnesses should be inspected as part of an appropriate maintenance program. Particular attention
should be given to areas near moving joints, cable guides, protective covers, connector locations, and
other points where mechanical movement can influence cable condition.
Symptoms of a deteriorating manipulator harness may include intermittent axis signals, feedback errors,
communication interruptions, unexpected robot alarms, or loss of electrical continuity. However, these
symptoms can also originate from other components, so electrical troubleshooting should be performed
systematically.
When a harness replacement is necessary, the cable should be routed according to the intended robot
configuration. Connectors should be correctly positioned and secured, and the harness should not be
subjected to unnecessary tension or mechanical interference.
ABB 3HAC025054-001 is specifically identified as a manipulator harness for the IRB 6620.
Always verify the complete robot model, configuration, and part number before installation.
Electrical and mechanical installation should be performed by qualified personnel using the
applicable ABB technical documentation.
Related ABB IRB 6620 Documentation
ABB’s IRB 6620 documentation identifies 3HAC025054-001 within the robot’s spare-parts and cable
documentation. A related ABB circuit diagram also lists 3HAC025054-001 as the manipulator harness
for axes 1–6, confirming its position within the IRB 6620 electrical system.
The identification is particularly useful when tracing individual cable assemblies during robot
maintenance. Instead of treating the harness as a generic cable, technicians can use the ABB part
number to match the correct assembly with the robot’s service documentation and wiring information.
Conclusion
ABB 3HAC025054-001 is a Manipulator Harness designed for the ABB IRB 6620 industrial robot.
The assembly covers the robot’s axis 1–6 electrical harness system and provides the internal cable
connections required by the manipulator.
As an integral part of the robot’s electrical and mechanical infrastructure, the harness supports
reliable signal and electrical connections while following the movement of the six-axis manipulator.
Correct identification, routing, connector installation, and maintenance are important for maintaining
the intended performance of the ABB IRB 6620 robotic system.
评价
目前还没有评价